Designed for industrial use.
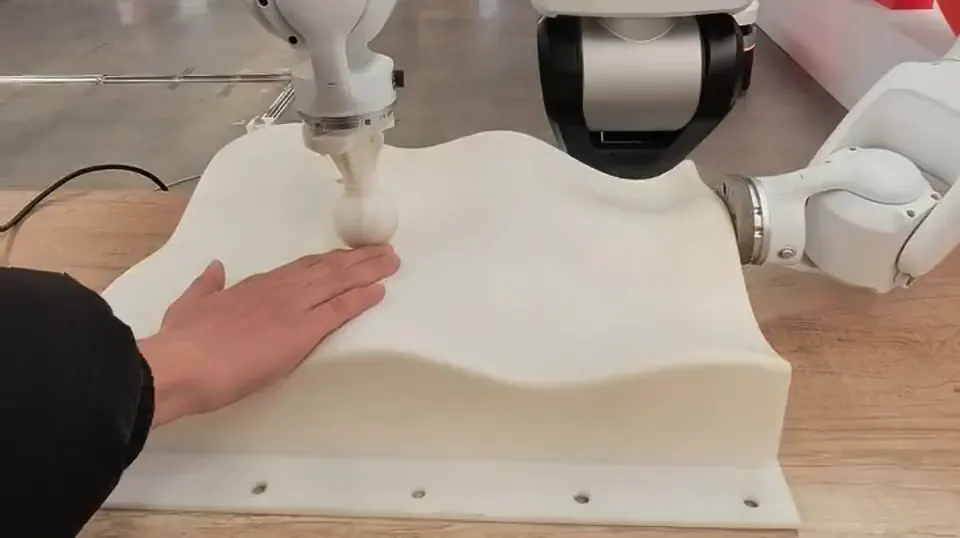
type01 is a wheel-based, dual-arm humanoid industrial robot with whole-body force control, an omnidirectional base and data processing directly on the robot.
Robot design.

Head and neck
Neck with 2 degrees of freedom (pitch, yaw), force-controlled joints. Stereo RGB-D camera, optional fisheye cameras for a 360° panoramic view, microphone and speaker array.
Arms
Two arms with 7 degrees of freedom each, force-controlled joints with joint force sensors. Payload 5 kg or 10 kg per arm, optional wrist camera.
Torso and legs
Waist with 2 degrees of freedom (rotation, pitch), legs with 2 degrees of freedom (folding, lifting). Working height 1493–2000 mm. Computing unit and service panel in the torso.
Mobile base
Omnidirectional chassis with four steered wheels, 1.5 m/s, docking accuracy ±10 mm. 2× 3D LiDAR with 360° coverage, ToF obstacle camera, two emergency stop buttons.
Grippers, sensors, software.
End effectors
- Electric grippers
- Dexterous robotic hands from various manufacturers (CAN-FD / RS485)
- Electric vacuum grippers
Sensors
- Fisheye cameras (3×)
- Chest stereo camera
- Wrist camera
- Microphone array with 360° voice pickup
- Speakers 2 × 10 W
Computing
- NVIDIA Orin NX 8 GB, 117 TOPS (standard)
- NVIDIA AGX Orin 64 GB, 275 TOPS
- NVIDIA Thor T5000, 2070 TFLOPS
Software and operation
- ROS2 and Python SDK
- Instruction via voice commands, SDK or HMI
- Status display via online portal
- Gamepad control (option)
type01 data sheet.
Versions with 5 kg and 10 kg payload per arm. Subject to technical changes.
| Basic data | |
|---|---|
| Dimensions (L × W × H) | 750 × 650 × 1493–2000 mm |
| Weight | 160 kg (5 kg version) / 180 kg (10 kg version) |
| Total degrees of freedom | 23 (neck 2, arms 7 × 2, waist 2, legs 2, chassis 3) |
| Operating environment | 0–45 °C, 0–90 % RH, non-condensing |
| Actuation | |
| Payload per arm | 5 kg or 10 kg depending on version |
| Force control | Whole-body force control for arms, waist and neck |
| Force sensing | Joint force sensors |
| End effectors | Electric grippers, dexterous hands, electric vacuum grippers (optional) |
| Chassis | Omnidirectional, 4 drive wheels |
| Max. travel speed | 1.5 m/s |
| Docking accuracy | ±10 mm |
| Perception | |
| 3D navigation LiDAR | 2 |
| Head stereo camera | 1 |
| Fisheye cameras | 3 (optional) |
| IMU | 1 |
| Chest stereo camera | 1 (optional) |
| Wrist camera | optional |
| Microphone array | 4 microphones, 360°, noise and echo cancellation (optional) |
| Speakers | 2 × 10 W (optional) |
| Power | |
| Battery capacity | 2 × 18 Ah, 36 Ah total |
| Charging methods | Direct charging, battery swap, autonomous charging (charging station optional) |
| Runtime | 4 h |
| Charging time | 2 h (10–90 %) |
| Charger output | 54.75 V, 10 A |
| Control | |
| Communication | Wi-Fi 2.4/5 GHz, Bluetooth, 5G (optional) |
| Computing (select one) | NVIDIA Orin NX 8 GB / AGX Orin 64 GB / Thor T5000 |
| Software | ROS2 and Python SDK |
| Safety and other | |
| Emergency stop | E-stop buttons on the robot, external e-stop (connector reserved), wireless e-stop (optional) |
| Service ports | HDMI, USB 2.0, RJ45 |
| LED light strip | Equipped |
| Standards and certification | [PLACEHOLDER: CE / Machinery Directive / CRA] |
Service from Moosdorf.
Stadler Technik handles commissioning, maintenance and repair. During operation, the robot status is displayed via an online portal.
- Availability
- [PLACEHOLDER: service hours]
- Response time
- [PLACEHOLDER: response time]
- Maintenance contracts
- [PLACEHOLDER: contract models]
- Remote maintenance
- [PLACEHOLDER: remote maintenance via online portal]
- Location
- Stadler Technik, Moosdorf, Upper Austria
Enquiry about your deployment.
Describe your application. You will receive a technical initial assessment and a recommendation for the suitable way to work.

+43 7748 33101
info@crewbotix.at
Stadler Technik GmbH · Moosdorf